Categories
Projects SPARUS II AUV Uncategorized

IQUA Robotics at REPMUS 26

IQUA Robotics wrapped up its fifth consecutive REPMUS, once again proving the SPARUS II AUV in mine countermeasures and seabed mapping operations.

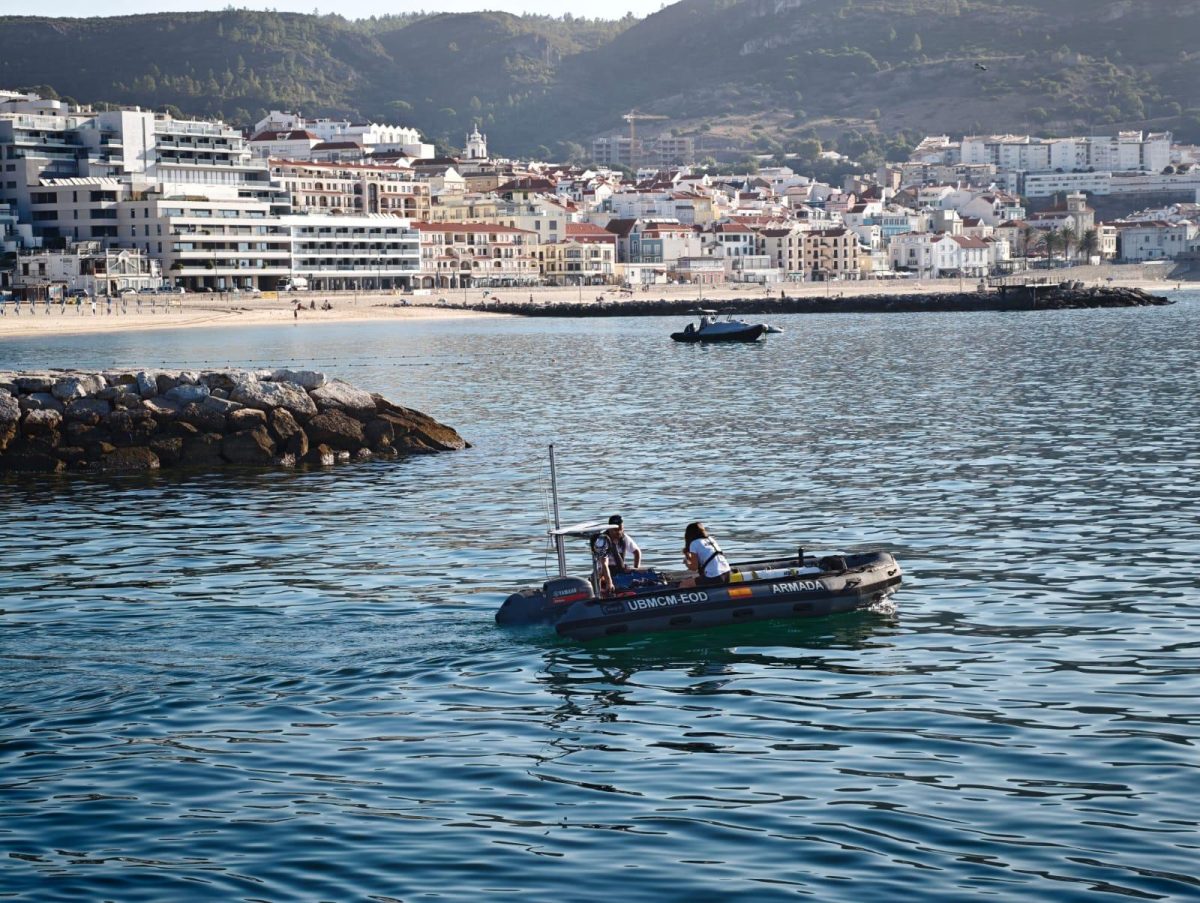
From 3 to 24 September 2026, the IQUA Robotics team was based in Sesimbra, Portugal, working alongside the Spanish Navy’s Mine Countermeasures (MCM) group. Over the exercise, the company’s SPARUS II AUV ran 16 different MCM serials, detecting many potential contacts and confirming the presence of multiple mines. For the first time, IQUA also worked with the Rapid Environmental Assessment (REA) group and took part in the exercise’s tactical phase. The vehicle was configured with a Blueprint Subsea forward-looking sonar, a Norbit multibeam echosounder and an optical camera system developed in-house by IQUA.


Detect and identify in a single mission

At the core of IQUA’s participation was the MCM pipeline, which combines detection and identification in a single autonomous mission. The vehicle is programmed to follow a search pattern, automatically detect contacts in the forward-looking sonar imagery, replan in real time to inspect each one with sonar, multibeam and camera, and then resume its initial search pattern.

This year’s main novelty was a new AI-based detector for the sonar imagery, which produced far fewer false positives than the detector used in previous editions. Moreover, during each contact inspection, an AI classifier labelled the contact as mine or non-mine from the optical images, correctly identifying every mine deployed for the exercise, and reporting the result in real time through the acoustic link. When the vehicle surfaced, the camera images, high-frequency sonar images and multibeam point clouds gathered during each inspection were immediately available for operators to identify every object, along with a semi-automatically generated APP-11 report of the findings.
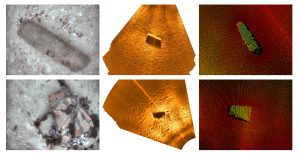
Image 1. Combined detection and identification missions using the new AI algorithms enabled the identification of multiple exercise mines, including targets deployed for the current exercise and legacy mines from previous years, which offered more realistic target characteristics. Shown above are inspection details for two of these targets, including optical imagery, a high-frequency forward-looking sonar (FLS) mosaic, and a multibeam echosounder point cloud.


IQUA also took the opportunity to take part in SPYTE (Sonar PY-curve Test), a test organized by the Swedish Armed Forces to evaluate detection and classification probability. As a result, the company obtained the probability-of-detection curve of the forward-looking sonar, a key input for assessing risk in MCM operations.


Interoperability with STANAG 4817

Together with the US Navy’s CTG 68.3, IQUA successfully demonstrated STANAG 4817 Vol. 3 interoperability. A US REMUS vehicle searched two of the designated MCM exercise areas with side-scan sonar and sent identification tasks to the SPARUS control station using STANAG 4817 messages. For each identification task received, the control station automatically generated a reacquisition mission, and the vehicle reacquired every contact in under 10 minutes, confirming its nature with optical imagery while the REMUS continued surveying. The time saved, compared with carrying out detection and identification as two separate phases, points to the future of collaborative missions and the importance of system interoperability.


Mapping critical infrastructure

In IQUA’s first collaboration with the REA group, SPARUS mapped the port of Sesimbra and an area crossed by a communications cable. In single missions it produced bathymetry, acoustic maps and optical mosaics, processed quickly with QPS Qimera and IQUA’s in-house SoundTiles and OpticTiles software. The results showcased the vehicle’s capability for multimodal data gathering and rapid product generation, which is key to the automated assessment of critical infrastructure.
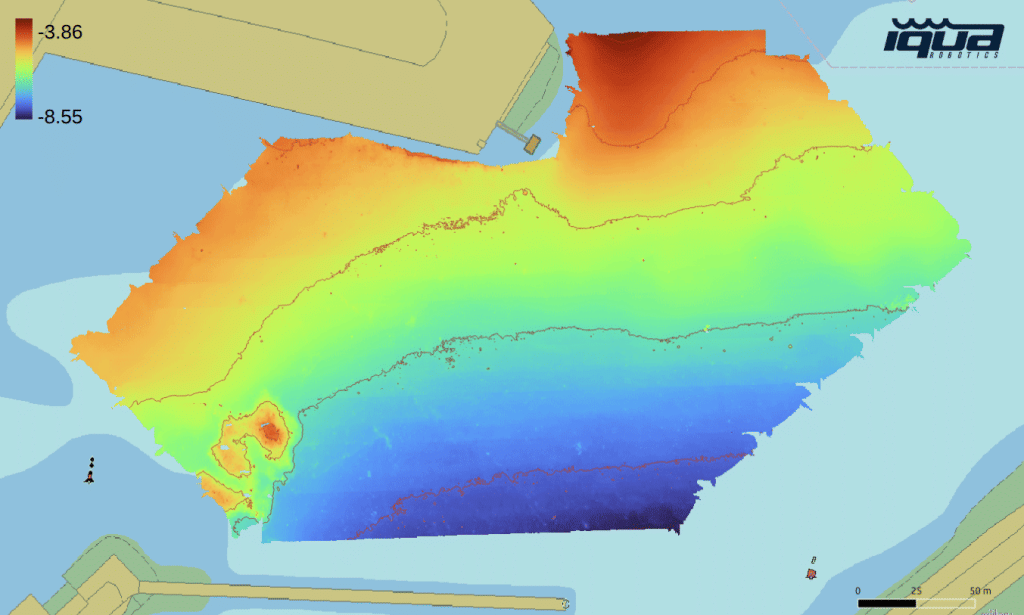
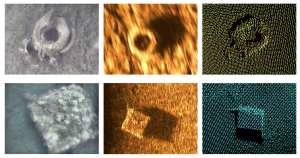
 

Image 2. Multimodal data collected at Sesimbra harbour, showing maps generated shortly after mission completion and details of objects across the different sensor modalities.


Beyond the serials 

Throughout the exercise, IQUA supported the Spanish Navy’s MCM group, which operates two SPARUS II units, and joined them in the tactical phase to identify contacts in assigned areas. The team also welcomed observers on board during some of their serials and engaged with representatives from other navies and companies. In addition, IQUA collaborated with other industry partners, processing their forward-looking sonar data with its SoundTiles software to produce acoustic maps.


Looking ahead to REPMUS 27

REPMUS 26 provided IQUA with valuable data and lessons to keep improving its algorithms and operations. IQUA Robotics would like to thank the Spanish Navy for its support throughout the exercise. See you at REPMUS 27!

Categories
Events Projects R&D projects Sparus II

SPARUS II AUVs in SPANISH MINEX

From the 5th to the 16 of May 2025 the Spanish Navy hosted the multinational exercise SPANISH MINEX-25 that took place in the Balearic Islands waters. 


SPANISH MINEX is an annual exercise that takes place in Palma (Spain) with the aim of testing systems in a collaborative environment for Mine Countermeasures (MCM). Organized by the Armada, the exercise included this year the participation of Belgium, USA, France and Italy, amongst others. This year we had the chance to actively participate in SPANISH MINEX alongside our clients, the Spanish Navy (Armada) and the University of the Balearic Islands (UIB).

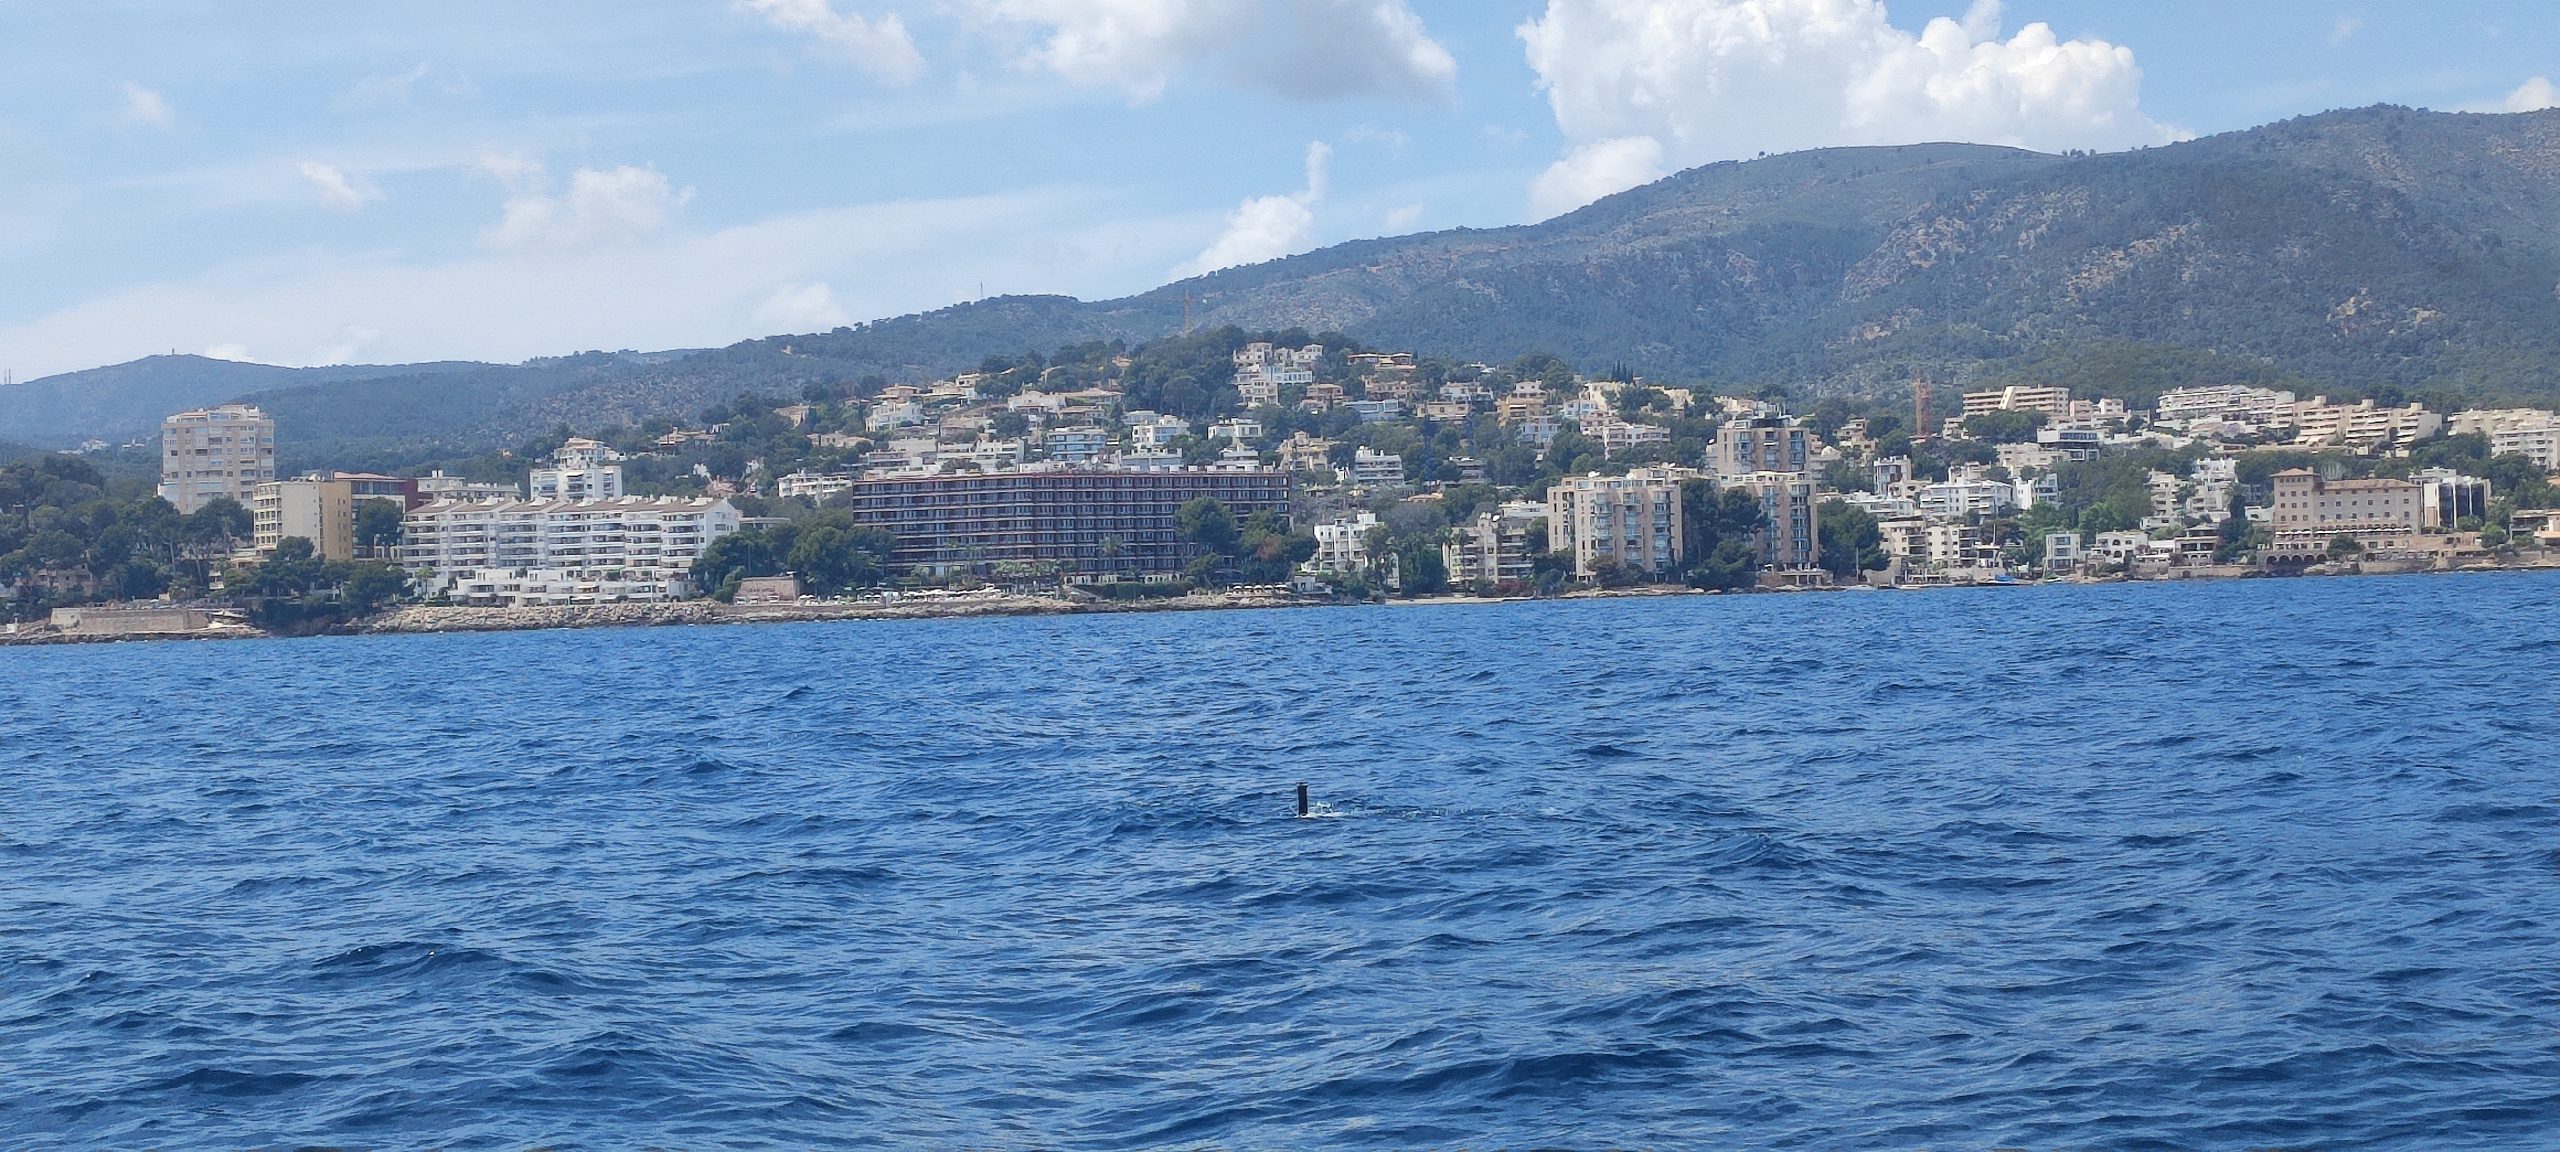
Figure 1. SPARUS II AUV ORAT surfacing after its mission in front of Porto Pi area (Mallorca).


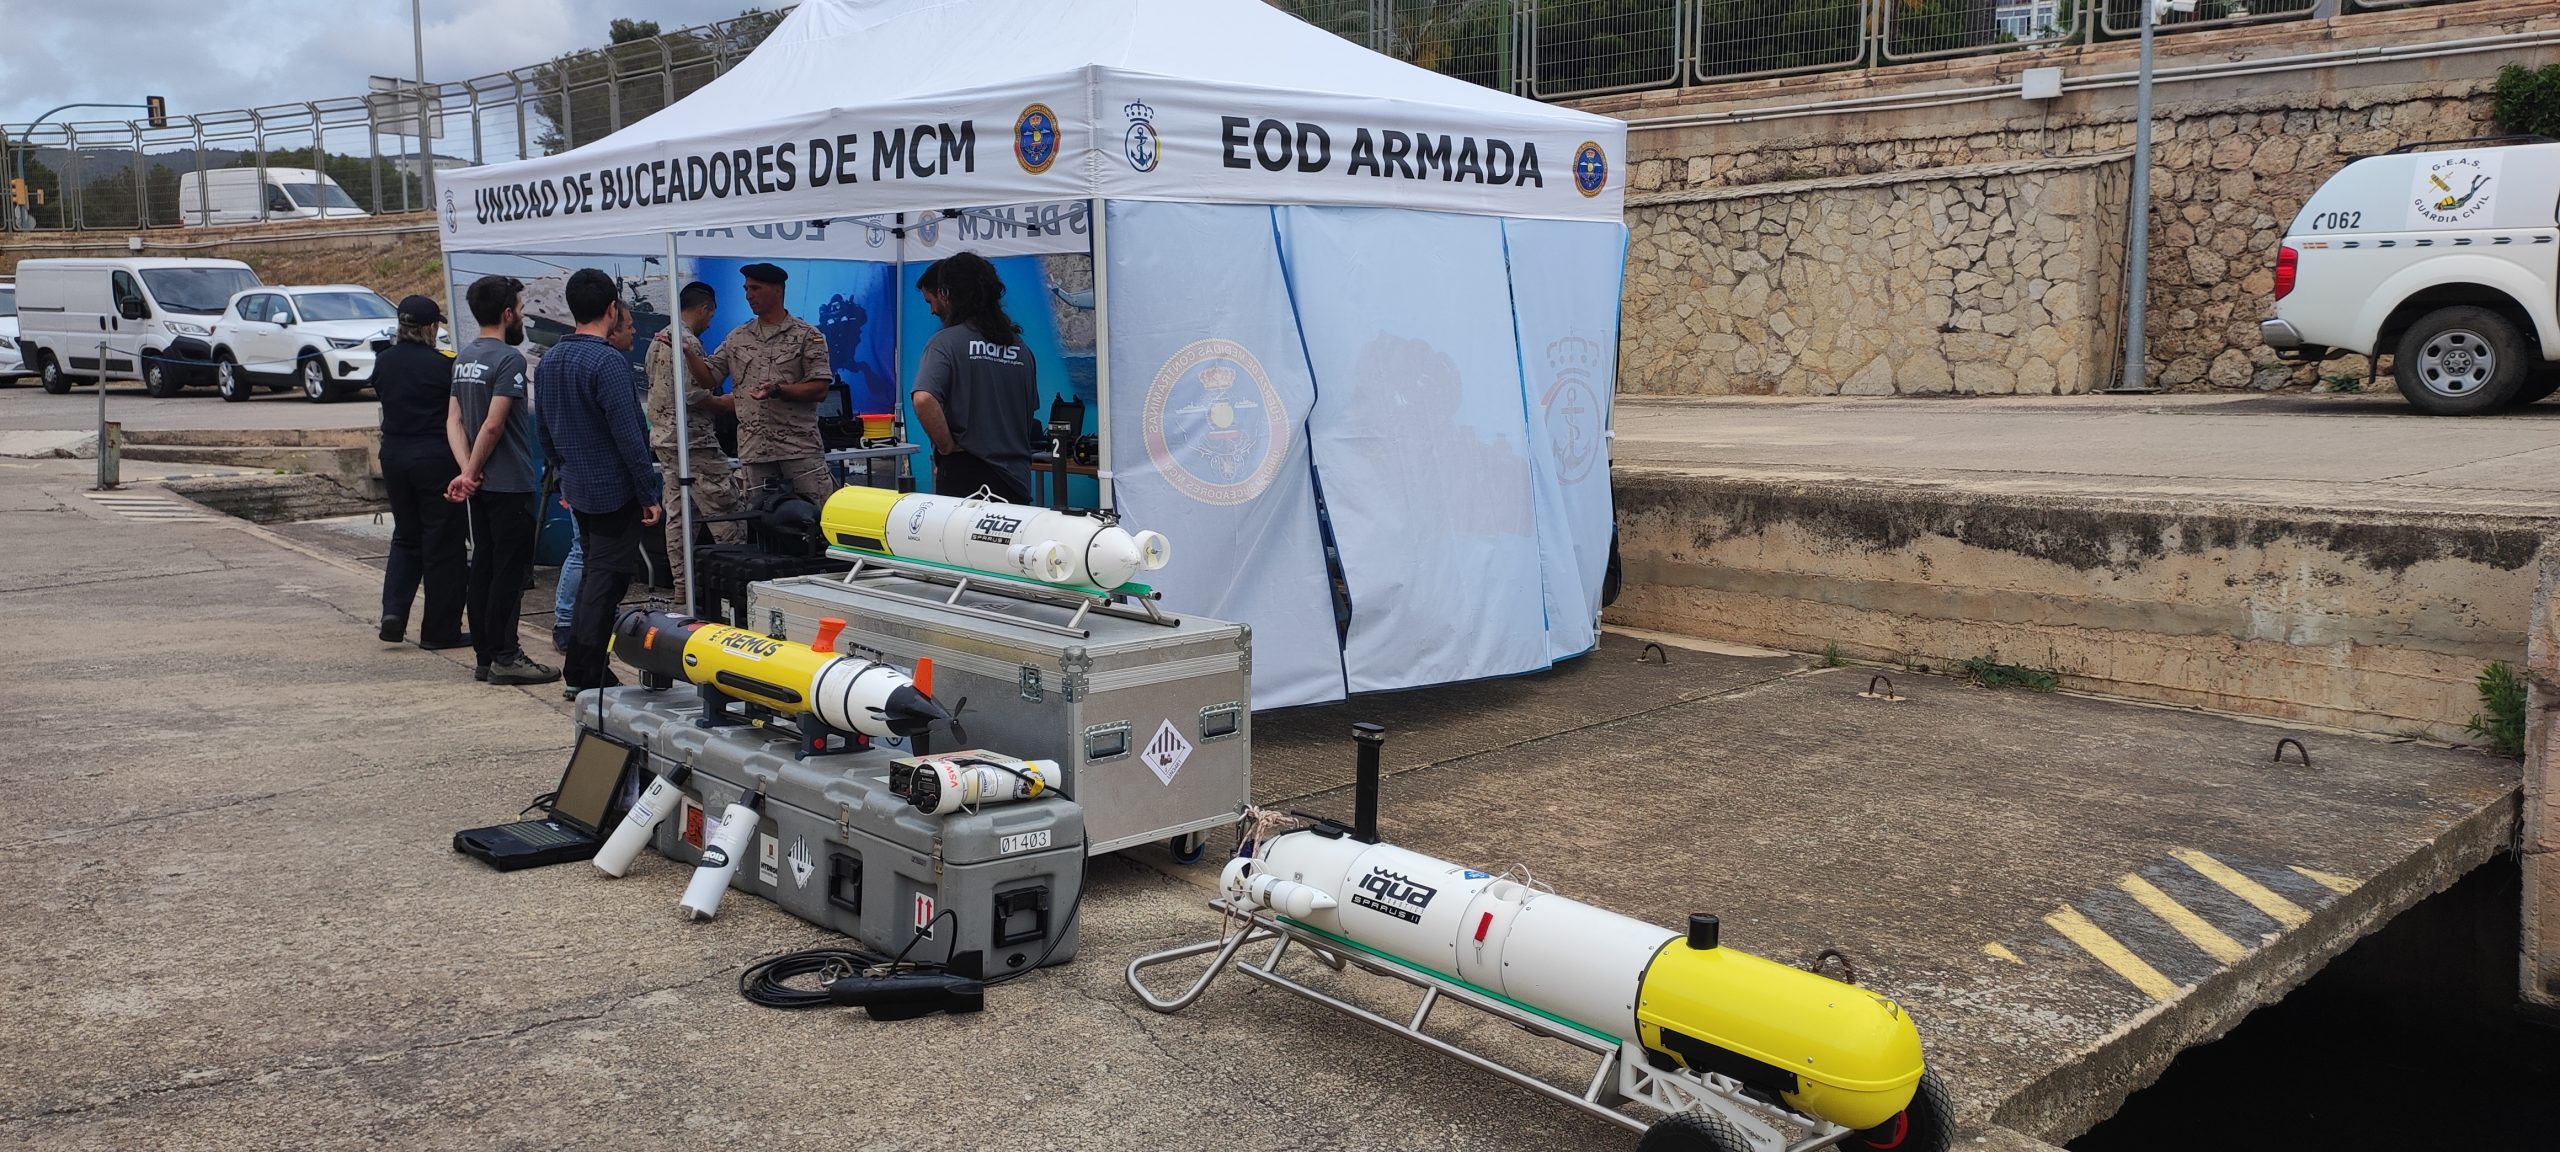
The Armada was operating the two SPARUS II AUV units that they acquired back in 2023 for MCM applications. Besides autonomous underwater vehicles, the Spanish Navy tested underwater detection systems on board of its vessels together with divers specialized in mine neutralization.

Figure 2. Part of the AUVs that participated in SPANISH MINEX-25.


SPARUS II AUV ORAT is one of the most recent units that we have manufactured, it is the second unit of UIB fleet and it was conceived to be a multimodal mapping platform. With an improved navigation system incorporating an Exail INS, ORAT’s payload is composed by a multibeam echosounder from Norbit, a side scan sonar from Atlas Marine Sonic and a stereo camera system with lights developed by the IQUA team and especially designed for this particular payload configuration. Our team operated the vehicle together with the team of engineers at the UIB with the aim of testing the unit in a realistic scenario for MCM.

Figure 3. SPARUS II AUV ORAT configuration.


The results obtained prove the capability of the vehicles for gathering accurate data in an efficient manner, allowing the team to produce multiple complementary maps of the seafloor, automatising part of the mine detection process.

Figure 4. Shipwreck area mapped using multi beam and side scan sonar.

Figure 5. Sewage pipe area mapped using side scan sonar, multi beam and stereo camera system.


Sources:
Spanish Navy

Categories
Events Sparus II

Use case: SPARUS II AUV for critical underwater infrastructure inspection

99% of the communications occurring in the world today happen through underwater fiber optic networks. There are more than 420 submarine lines in the world, totalling 1.3 million kilometers which allow us to communicate and operate in the way we do as a society. These infrastructures are equally important today as oil and gas pipelines, since the volume of financial transactions, very relevant to the system, run through these underwater cables. 

Underwater environments are hazardous and especially difficult to monitor for two main reasons: firstly, the locations themselves may be areas of difficult access either for their depth, the existing currents, or even the movements of the seafloor and, secondly, the technologies that are commonly available in the surface, like GPS or WiFi will not work. So, there is a clear vulnerability for the security of these infrastructures. 

On average, there are over a hundred breaks of submarine cables every year, caused in general by the fishing boats that pull the anchors. But, being identified as critical infrastructure, they are also a target for potential sabotage. The first attacks registered date back in 2017. Although they remain unknown to the general public, they are no less worrying and prove the capacity of external powers to separate Europe from the rest of the world. 

Keeping this context in mind and in the framework of “Robotic Experimentation and Prototyping using Maritime Uncrewed Systems” (REPMUS) exercise, multiple technologies for automatic underwater cable detection and inspection were tested in a simulated complex scenario. Led by NATO, the event takes place annually in the Lisbon coastal area hosted by the Portuguese Navy.  

Figure 1. SPARUS II AUV deployed in the area of interest. ©IQUA robotics  

IQUA robotics participated in REPMUS 2023 exercise, invited by the Spanish Navy to prove the capabilities of its vehicle SPARUS II AUV for the described mission. The goal of the mission was to, in a completely autonomous way, locate the cable and inspect it from nearby to be able to identify potential threats to it. 

One of the characteristics of the SPARUS II AUV is its possibilities to be configured according to the mission needs, in this case, the vehicle was equipped with an optic camera system developed by IQUA and a commercial forward looking sonar. 

Figure 2. SPARUS II AUV configuration for CUI inspection. ©IQUA robotics

The IQUA Robotics strategy for addressing the assigned task consisted of the following steps:

  • Deploying the AUV in proximity to the supposed cable location.
  • Executing a predefined autonomous mission within the area, while employing an automated algorithm to continuously analyze incoming forward-looking sonar data to detect the cable presence.
  • Without human intervention and without requiring resurfacing, the AUV automatically plans a trajectory connecting all potential cable locations observed in the sonar images.
  • The AUV then follows the planned trajectory close to the seafloor, enabling the camera system to capture images of the cable along its route.
  • Returning to the surface with the collected data.

Figure 3. Schematic of the approach taken for capturing the cable data for inspection. ©IQUA robotics

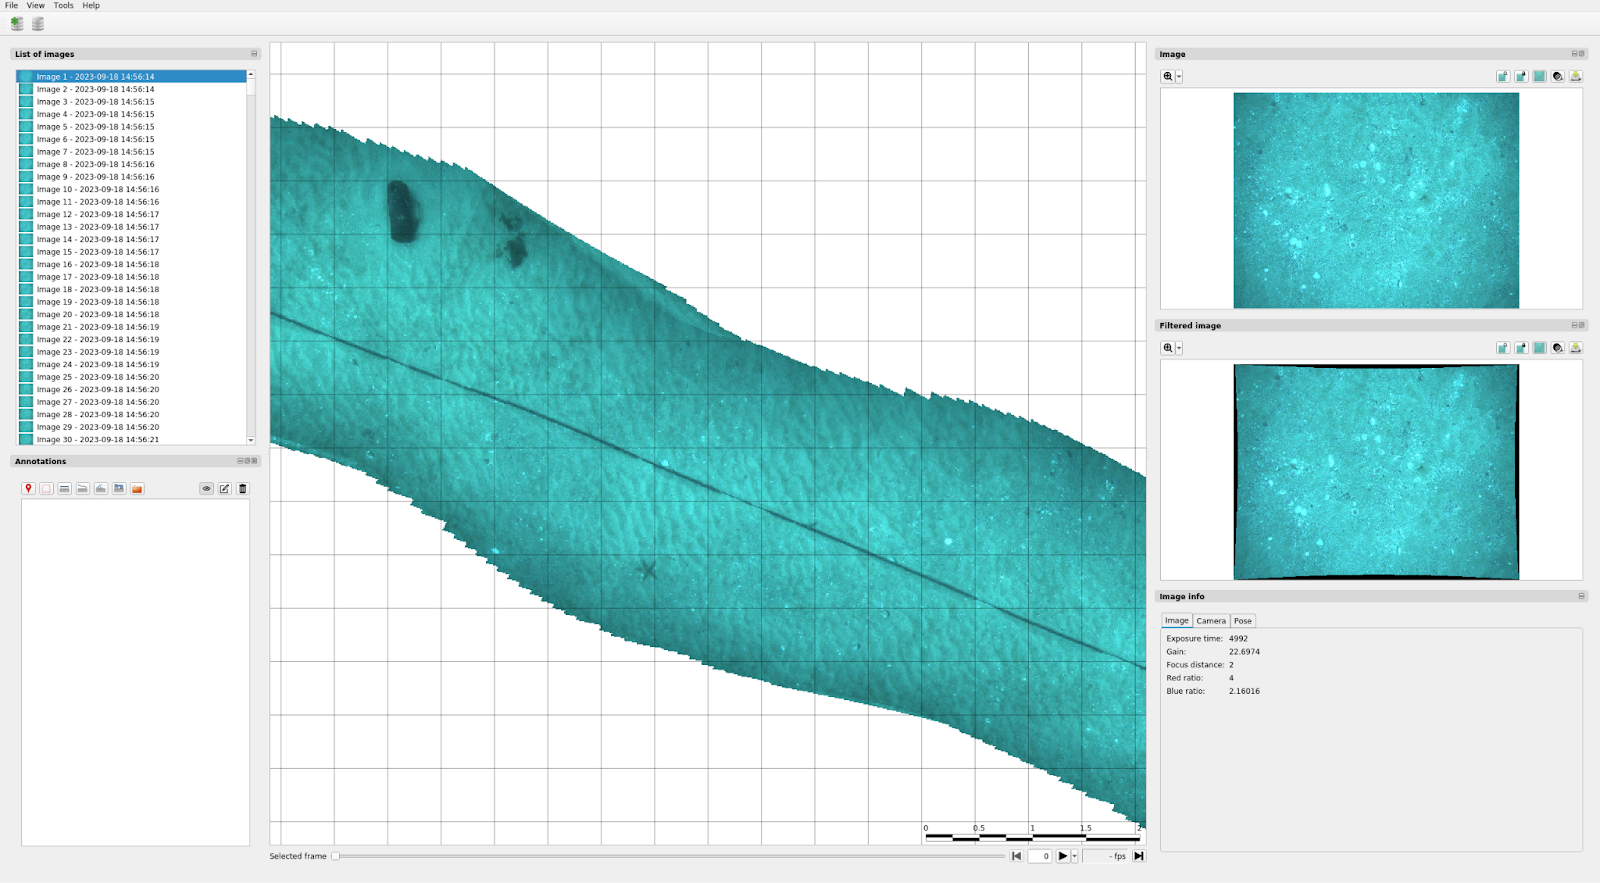
Throughout the mission, real-time monitoring was conducted from the surface through the IQUAview user interface, which visualized data transmitted by the AUV via an acoustic modem. The collected data allowed the creation of acoustic maps and visual reconstructions along the cable. 

Figure 4. Visualization from the control station of the obtained optic data off-line. ©IQUA robotics

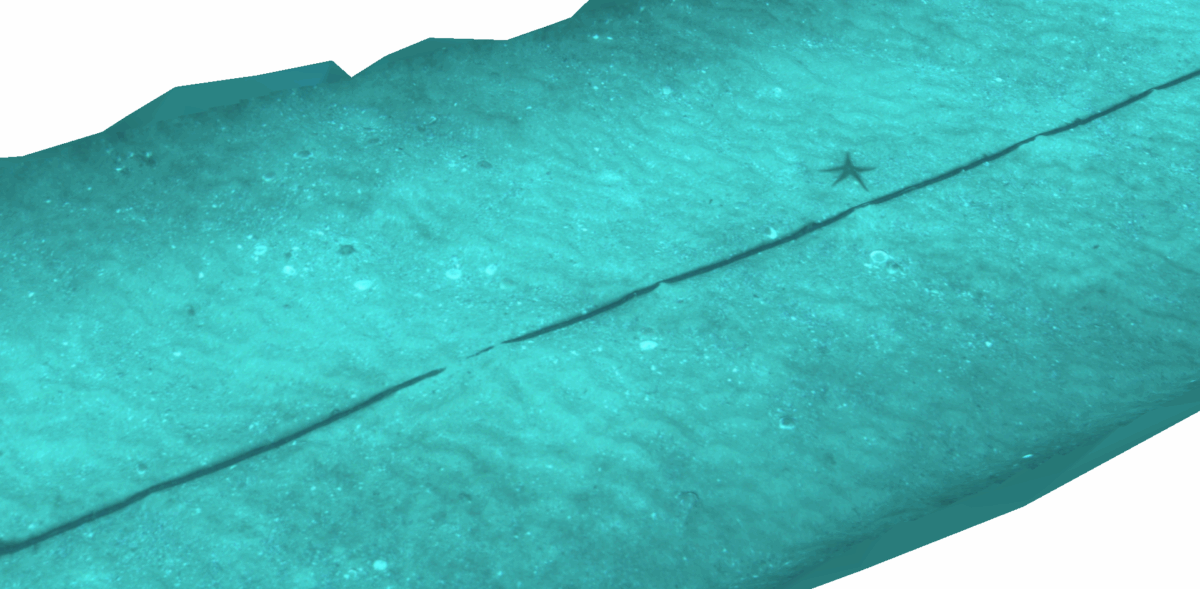
The image below shows a mosaic of approximately 150m long x 2.5m wide where one suspicious element is clearly identified (60x20cm) and can be seen with high resolution for its interpretation. The capability of finding such objects closeby the cables without human intervention can be key to the future of the security of critical underwater infrastructures. 

Figure 5. Mosaic created of the inspected area available in high resolution for its interpretation. ©IQUA robotics

Sources:

Submarine Cables: Risks and Security Threats (2022) 

NATO exercises with new maritime unmanned systems in Portugal (2023)